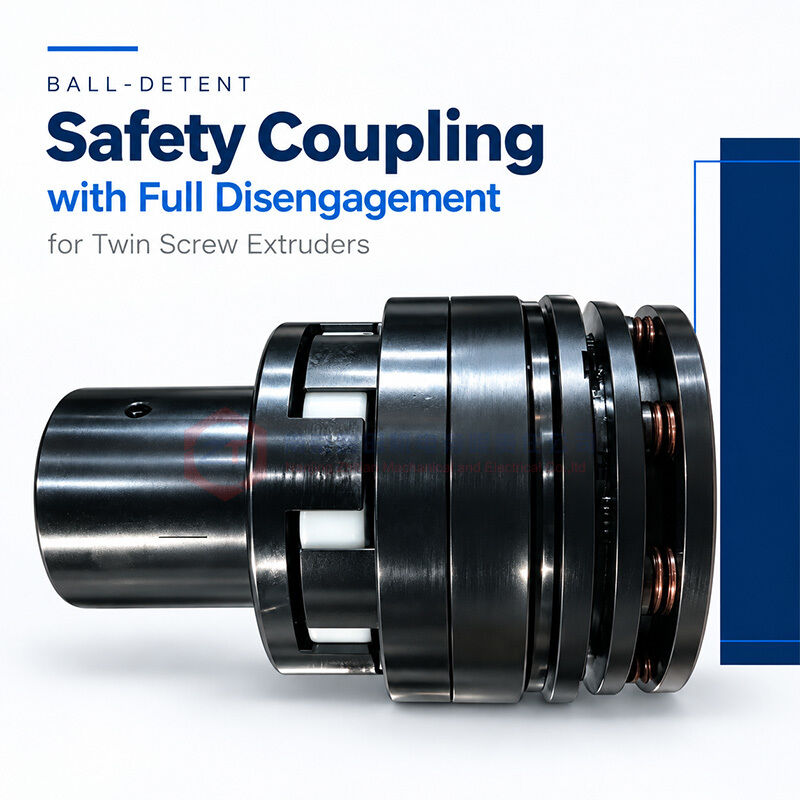
ZHITIAN supplies ball-detent safety couplings for installation between the motor and gearbox of twin screw extruders. The coupling transmits torque during normal operation and fully disengages when the specified overload torque is reached, separating the driving and driven sides.
The mechanism incorporates a circumferential arrangement of steel balls seated in matching pockets. On overload, the balls leave their pockets together, interrupting the torque transmission path.
After release, no residual driving torque is transmitted to the driven side, and the coupling does not automatically re-engage. This provides a defined separation between the motor and gearbox until the overload cause has been addressed and the coupling has been reset according to its operating instructions.

Full Disengagement Through a Ball-Detent Mechanism
During normal operation, the steel balls remain engaged in their corresponding pockets, allowing the coupling to transmit torque between the motor and gearbox.
When the applied torque reaches the specified release threshold, the balls move out of engagement. The driving and driven sides then separate completely.
This full-disengagement action interrupts the mechanical drive connection instead of maintaining torque transmission through continuous slipping. The input side can continue to rotate independently after release without driving the gearbox through the coupling.
The permissible free-running speed and duration must follow the specifications of the selected coupling.
Bidirectional Protection Verified Before Shipment
Each ZHITIAN torque limiter undergoes repeated forward and reverse torque tests on a dynamic torque test bench before shipment.
Testing verifies that the release torque remains within the customer-specified range in both rotational directions. This supports consistent overload protection where the application requires forward and reverse operation.
The inspection focuses on the actual release behavior rather than relying only on the nominal setting. Repeated testing checks whether successive release measurements remain within the agreed acceptance range.
Required release torque, acceptance limits, and any test documentation should be confirmed with the order. Where a numerical accuracy requirement applies, it should be stated explicitly in the technical specification.
No Automatic Re-Engagement After Overload
Once released, the coupling remains disengaged. It does not automatically reconnect the motor to the gearbox simply because the overload has decreased or the input side continues rotating.
This behavior allows the overload cause to be investigated before torque transmission is restored.
Before restarting, the equipment should be stopped and the cause of the overload addressed. The coupling is then inspected and reset according to the instructions for the supplied configuration.
Non-automatic re-engagement is a functional feature of this design. Resetting should be a deliberate maintenance action rather than an assumed consequence of continued motor rotation.
Optional Proximity Switch for Overload Detection
A proximity switch can be installed adjacent to the outer circumference of the signal ring to detect the release movement.
When the coupling disengages, the switch detects the change in ring position and sends a signal to the machine control system. When correctly connected and configured, this signal triggers a motor stop command.
The mechanical disengagement and the electrical stop signal perform different functions:
Mechanical disengagement interrupts torque transmission through the coupling.
The proximity switch reports the release condition.
The control system commands the motor to stop.
Actual motor stopping time depends on the drive controls, braking arrangement, and rotating inertia. Switch mounting and control integration should therefore be confirmed during installation planning.
Product Specifications
| Item | Specification |
|---|
| Product Type | Ball-detent safety coupling |
| Application | Twin screw extruder motor-to-gearbox connection |
| Torque Transmission Mechanism | Steel balls engaged in matching pockets |
| Overload Behavior | Full disengagement of driving and driven sides |
| Protection Direction | Bidirectional |
| Torque Transmission After Release | No residual driving torque transmitted to the driven side |
| Re-Engagement | Non-automatic; reset according to operating instructions |
| Input-Side Free Running | Permitted within the selected coupling specifications |
| Overload Detection | Optional proximity switch at the signal ring |
| Factory Testing | Repeated forward and reverse dynamic torque tests |
| Release Torque | Set and verified within the customer-specified range |
Six Parameters Required for Initial Selection
Please provide the following information for initial coupling selection and quotation:
| Required Parameter | Unit / Details |
|---|
| Motor Power | kW |
| Number of Motor Poles | e.g. 2, 4, 6, or 8 poles |
| Motor-Side Bore Diameter | mm |
| Motor-Side Bore Engagement Length | mm |
| Gearbox-Side Bore Diameter | mm |
| Gearbox-Side Bore Engagement Length | mm |
Bore engagement length refers to the axial shaft-to-hub fitting length on each side, rather than the overall coupling length.
For final selection, additional information may include the actual operating speed range, gearbox permissible input torque, starting conditions, and available installation space. Motor nameplate photographs and shaft drawings help verify the connection requirements.
The release setting is confirmed separately from the bore dimensions and must account for the protection requirements of the complete drive.
Frequently Asked Questions
Does this coupling provide protection in both rotational directions?
Yes. Forward and reverse release performance is checked through repeated dynamic torque testing before shipment against the agreed torque range.
Is torque still transmitted after the coupling releases?
The driving and driven sides fully disengage, interrupting the driving torque path. The input side can rotate independently within the specified free-running limits.
Will the coupling automatically reset?
No. It remains disengaged until reset according to the operating instructions after the overload cause has been addressed.
Does the proximity switch stop the motor directly?
The switch provides a release signal to the control system. The configured controls then issue the motor stop command.
Request a Selection and Quotation
Send ZHITIAN the six initial selection parameters, your required release torque range if available, and whether proximity-switch detection is required.
We will review the information and confirm the coupling configuration, shaft interfaces, torque acceptance range, inspection requirements, and delivery schedule.

 Your message must be between 20-3,000 characters!